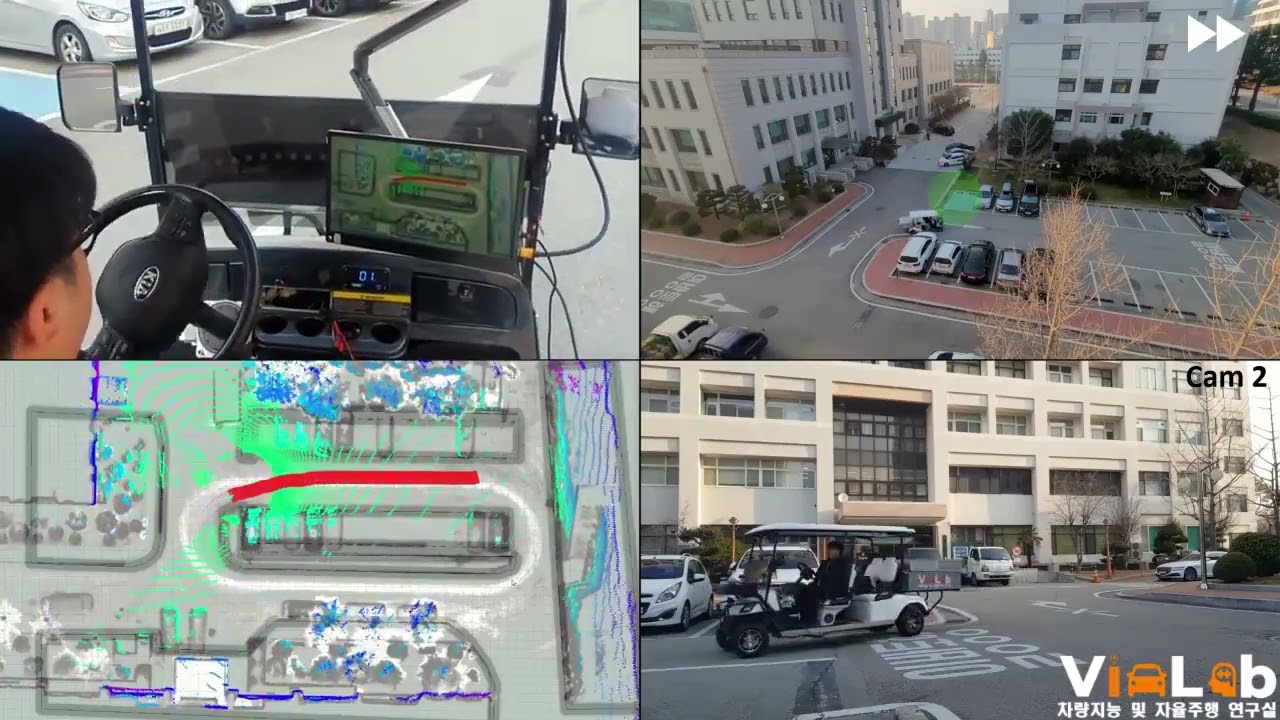
Exclusive Traffic AVP
Automated Valet Parking in Controlled Environment
Developed autonomous parking system using linear MPC algorithm with structured parking space management. Built a controlled environment where only autonomous vehicles operate, enabling systematic development and testing. Tested on actual autonomous vehicle platform in ROS environment.
Key Technologies
Control System
- Linear MPC: Model Predictive Control for precise path tracking and trajectory execution
- Stanley Controller: Alternative path tracking for comparison
- Pure Pursuit: Benchmark algorithm for performance evaluation
Parking Management
- Structured Parking Management: System for organizing and allocating parking slots
- Slot Selection: App-based selection of target parking spaces (empty spaces intentionally designated)
- Localization: Google Cartographer-based positioning (external implementation)
- Approach Planning: Optimized trajectories for parking entry
Implementation Details
- C++, Python, and ROS integration
- Gazebo simulation environment for controlled testing
- Real vehicle platform validation
- Comprehensive unit and integration testing
System Architecture
- Perception: LiDAR-based localization and slot detection
- Planning: Path planning for parking approach and execution
- Control: MPC-based trajectory tracking
- Management: Parking slot allocation and coordination